|
Yunwoo Lee I am a Tenure-track Assistant Professor at DGIST EECS, South Korea. Before joining DGIST, I was a Postdoctoral Fellow at Carnegie Mellon University Robotics Institute (CMU RI), where I work with Prof. Sebastian Scherer in AirLab. I did my Ph.D. from Seoul National University (SNU) under the supervision of Prof. H. Jin Kim. One of my work received 2025 IEEE T-ASE Best New Application Paper Award at ICRA 2026. |
|
ResearchI'm interested in Multi-Robot Autonomy, Motion Generation, and, Robotic Applications. |
|
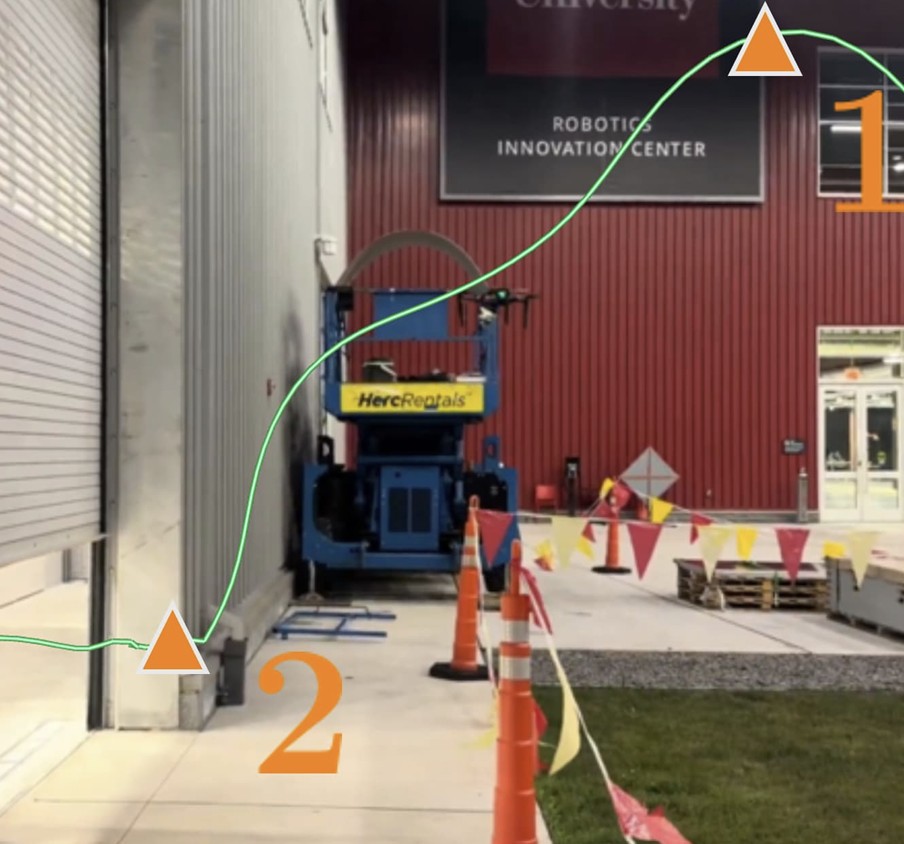
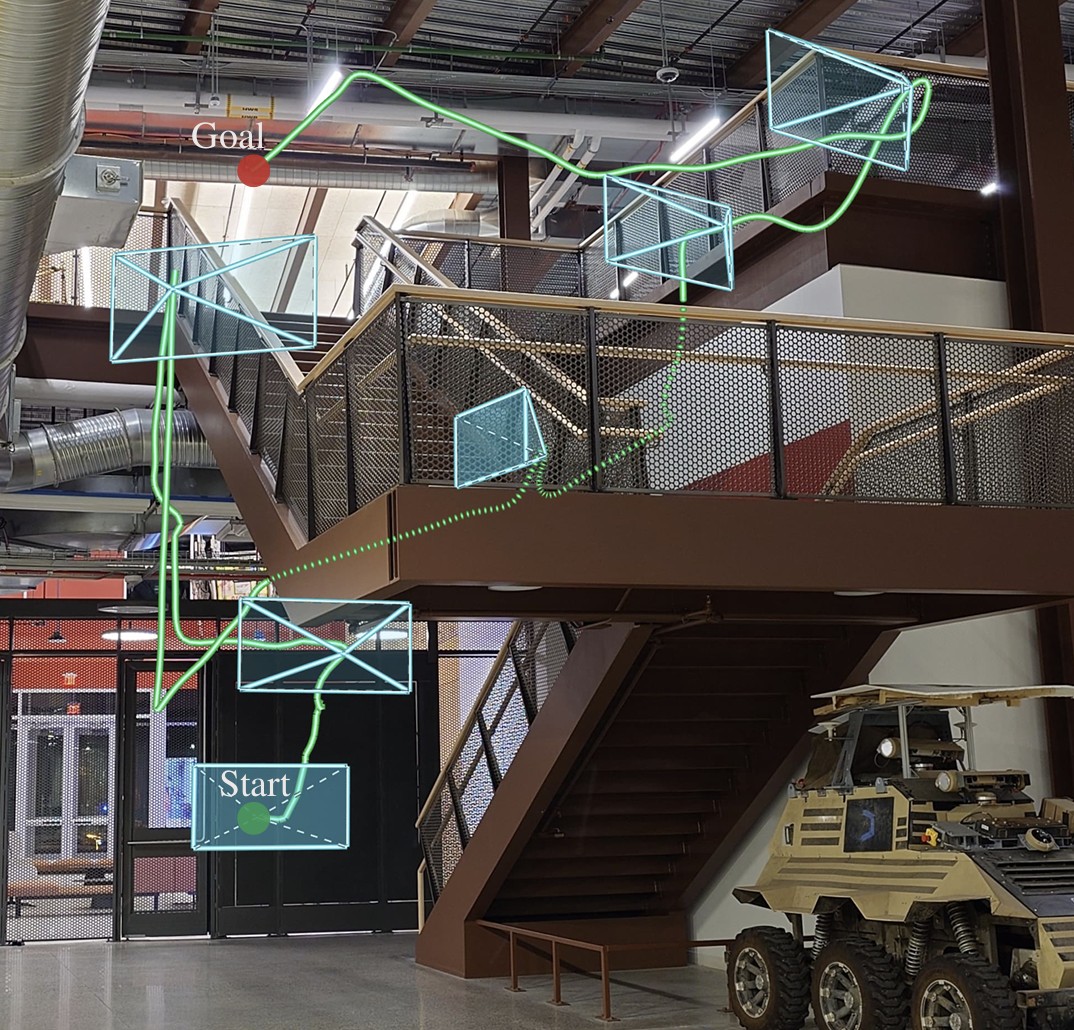
SCOPE: Field-of-View-Aware Path Planning in Unknown 3D Environments via Safety-Volume Certification
Junbin Yuan, Muqing Cao, Yunwoo Lee, Brady Moon, Sebastian Scherer arXiv, 2026 project page / arXiv This work introduces SCOPE, a field-of-view-aware planner that certifies the robot’s full safety volume before execution, enabling safe goal-directed navigation in unknown 3D environments. |
|
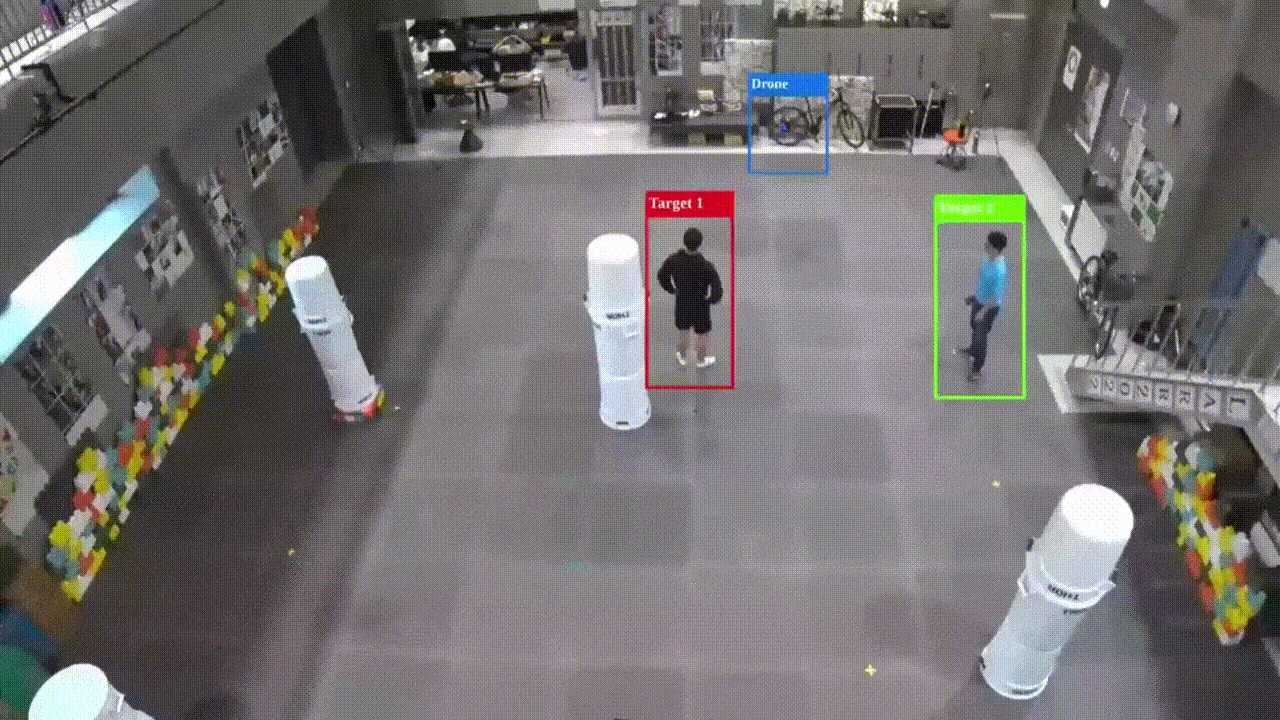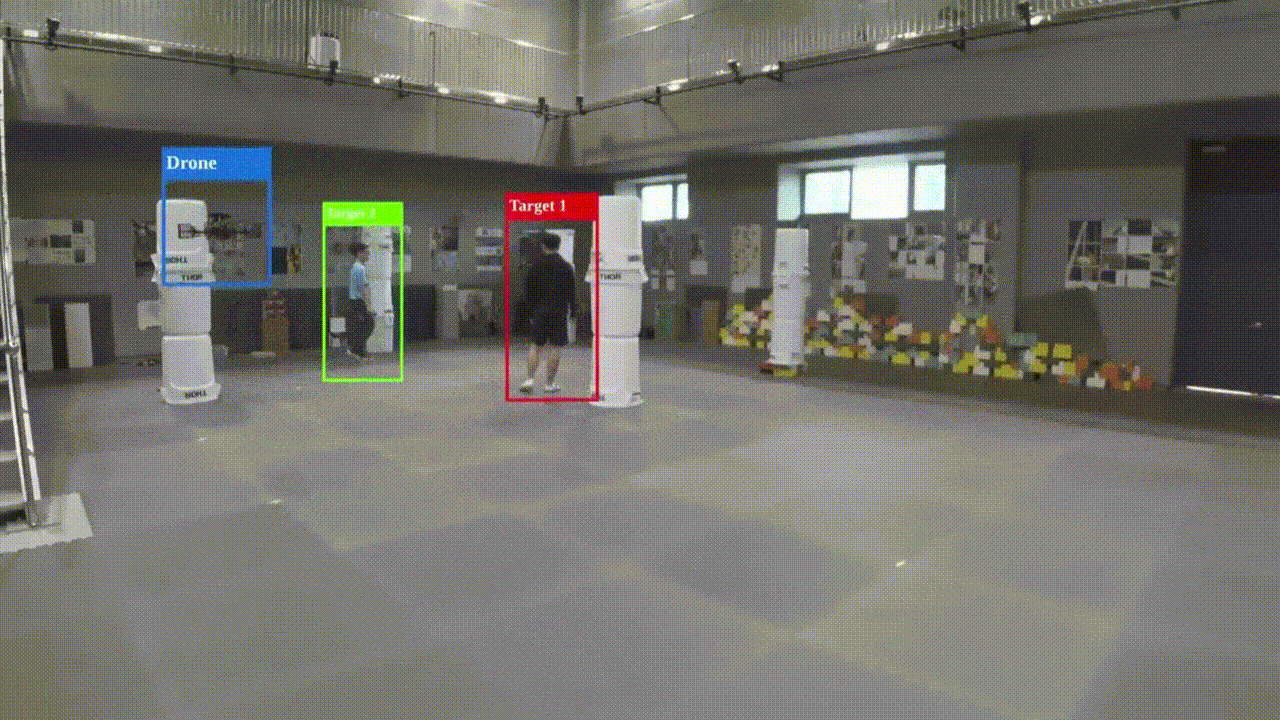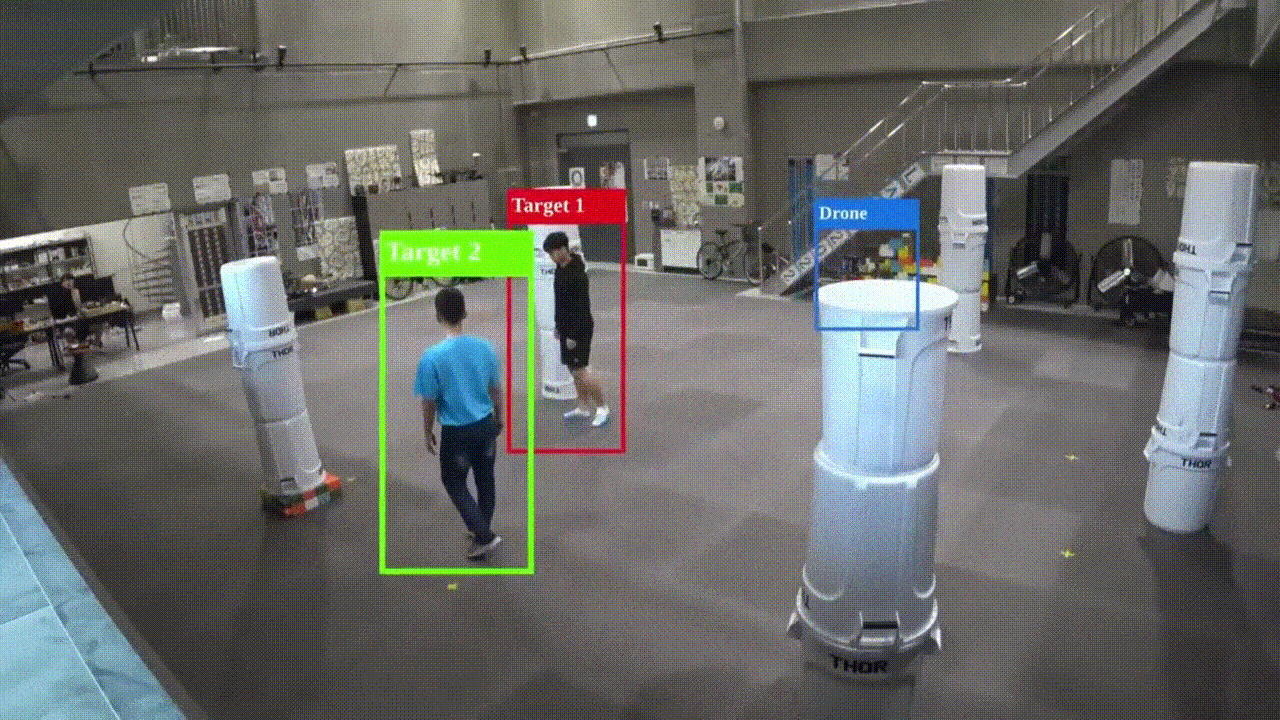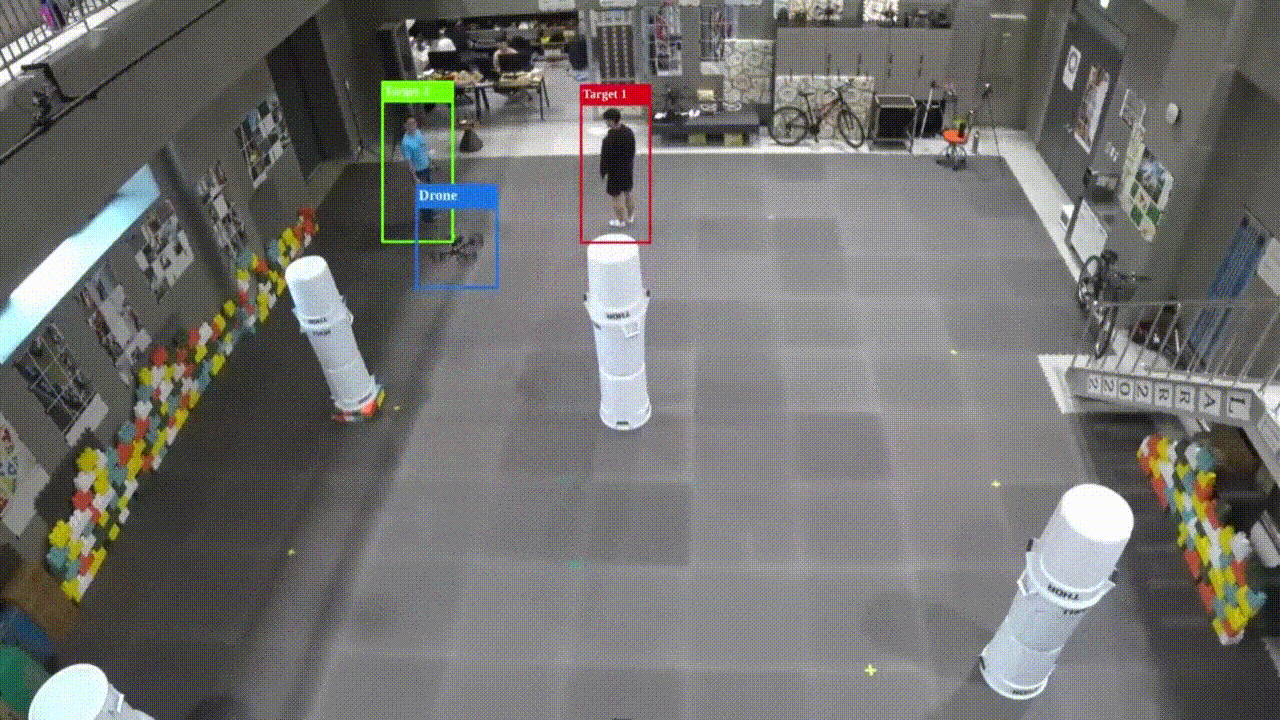
QP Chaser: Polynomial Trajectory Generation for Autonomous Aerial Tracking
Yunwoo Lee, Jungwon Park, Seungwoo Jung, Boseong Jeon, Dahyun Oh, H. Jin Kim IEEE Transactions on Automation Sciences and Engineering, 2025 IEEE Xplore This paper presents a asynchronous&distributed multi-robot trajectory planning framework that enables deadlock-free and collision-free quadrotor swarm with no communication during flight. |
|
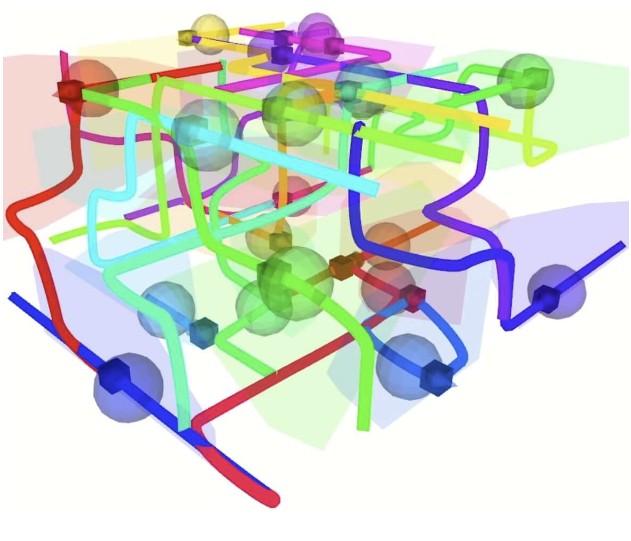
MC-Swarm: Minimal-Communication Multi-Agent Trajectory Planning and Deadlock Resolution for Quadrotor Swarm
Yunwoo Lee, Jungwon Park arXiv, 2025 arXiv This paper presents a asynchronous&distributed multi-robot trajectory planning framework that enables deadlock-free and collision-free quadrotor swarm with no communication during flight. |
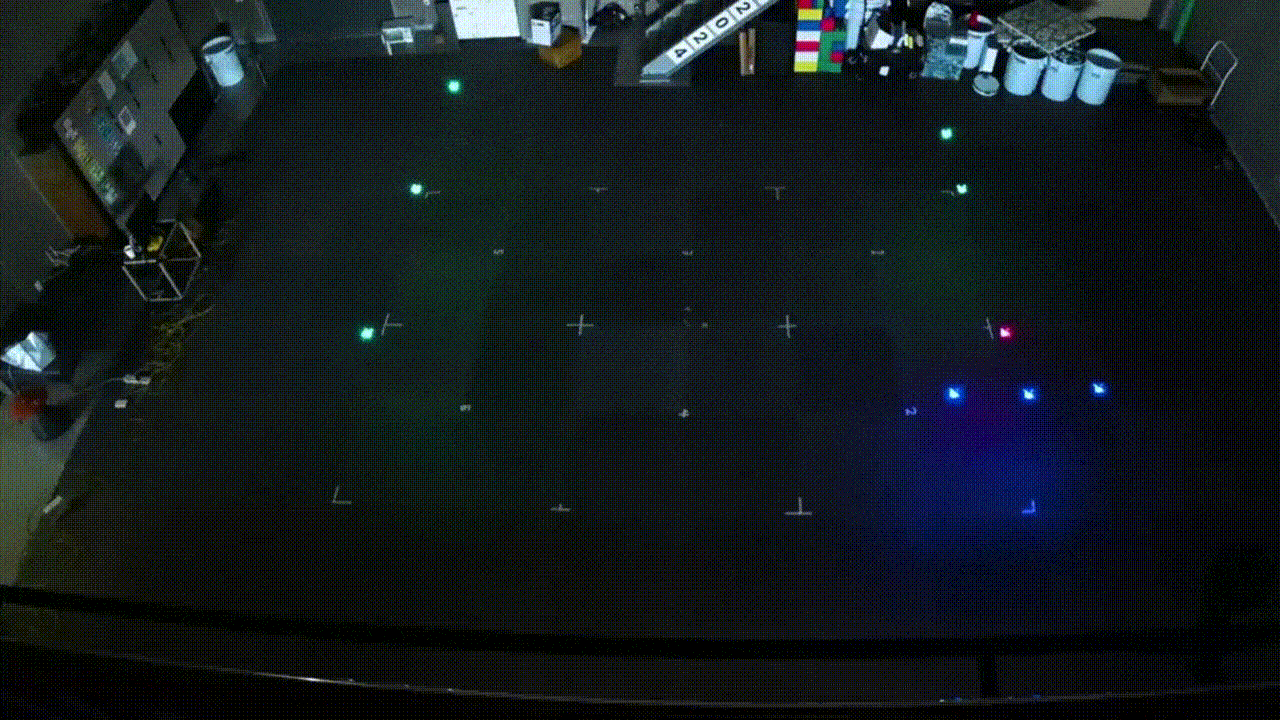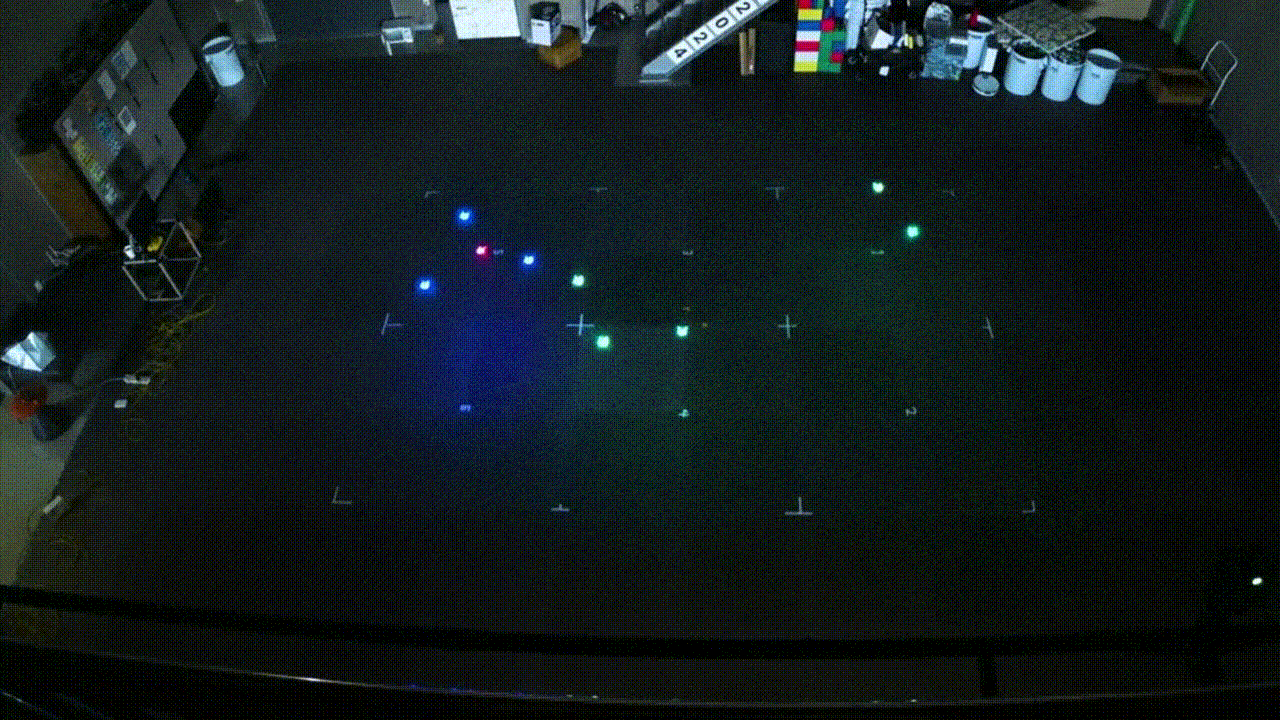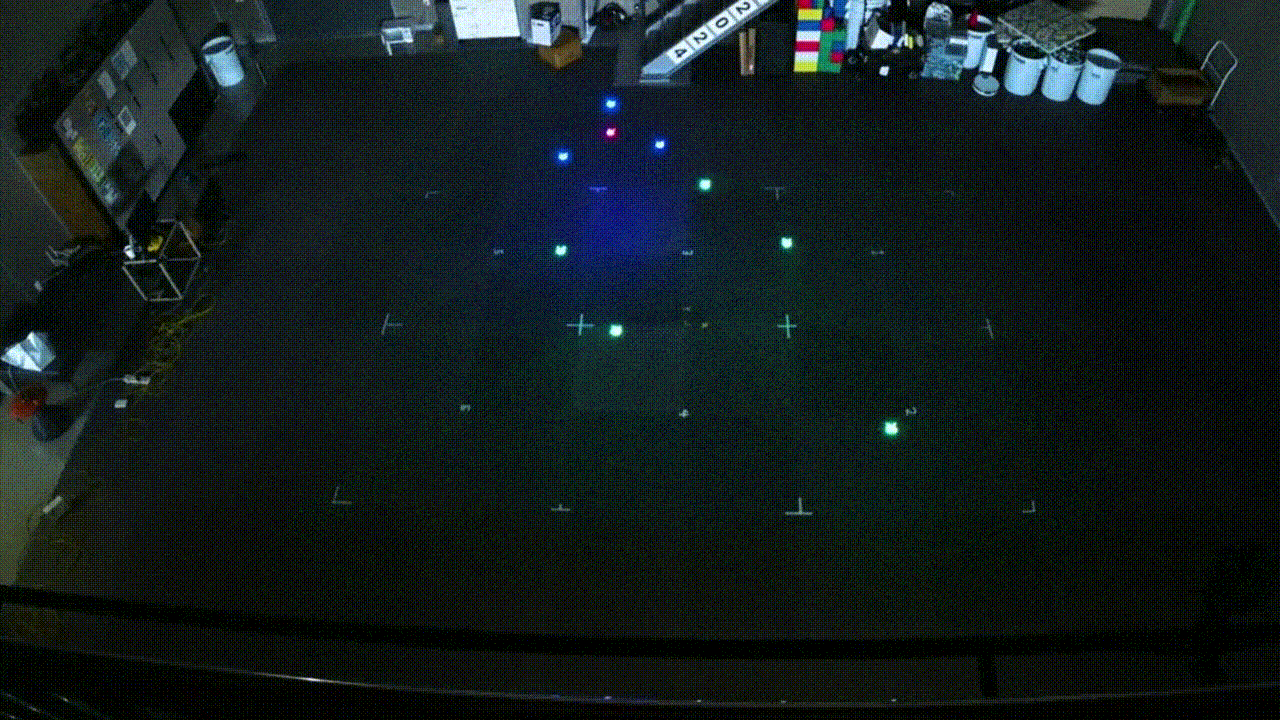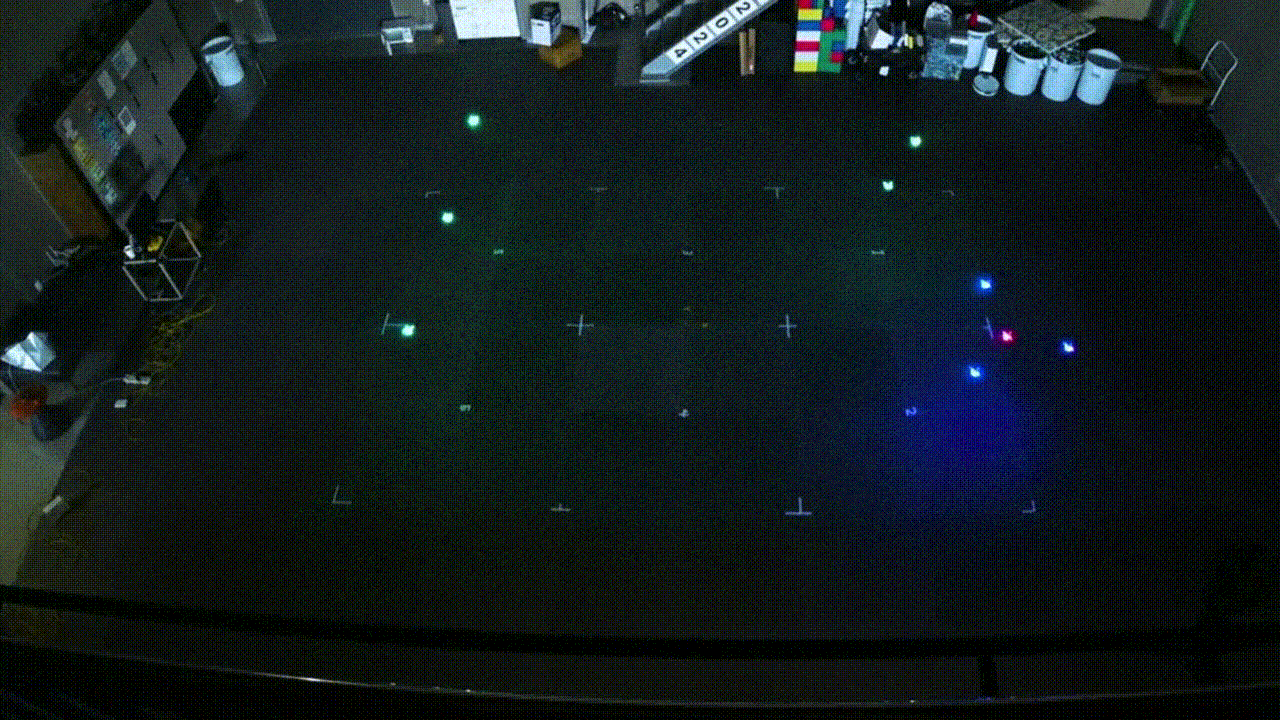
|
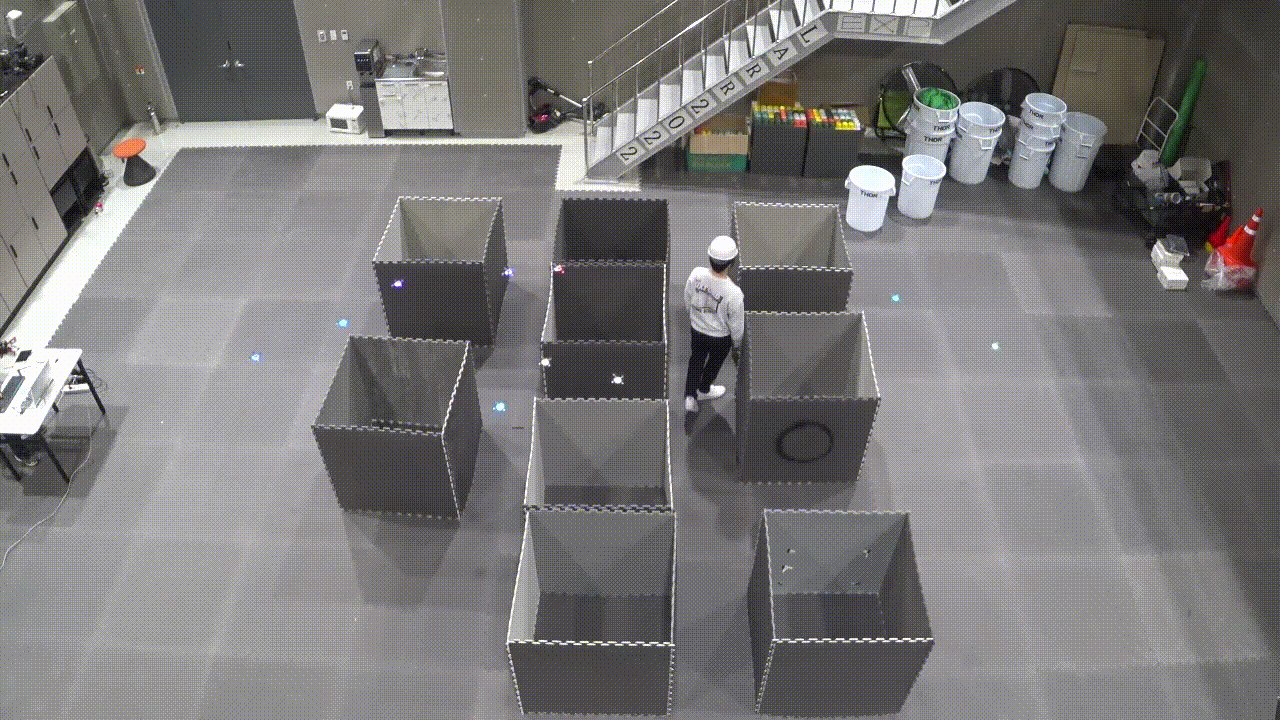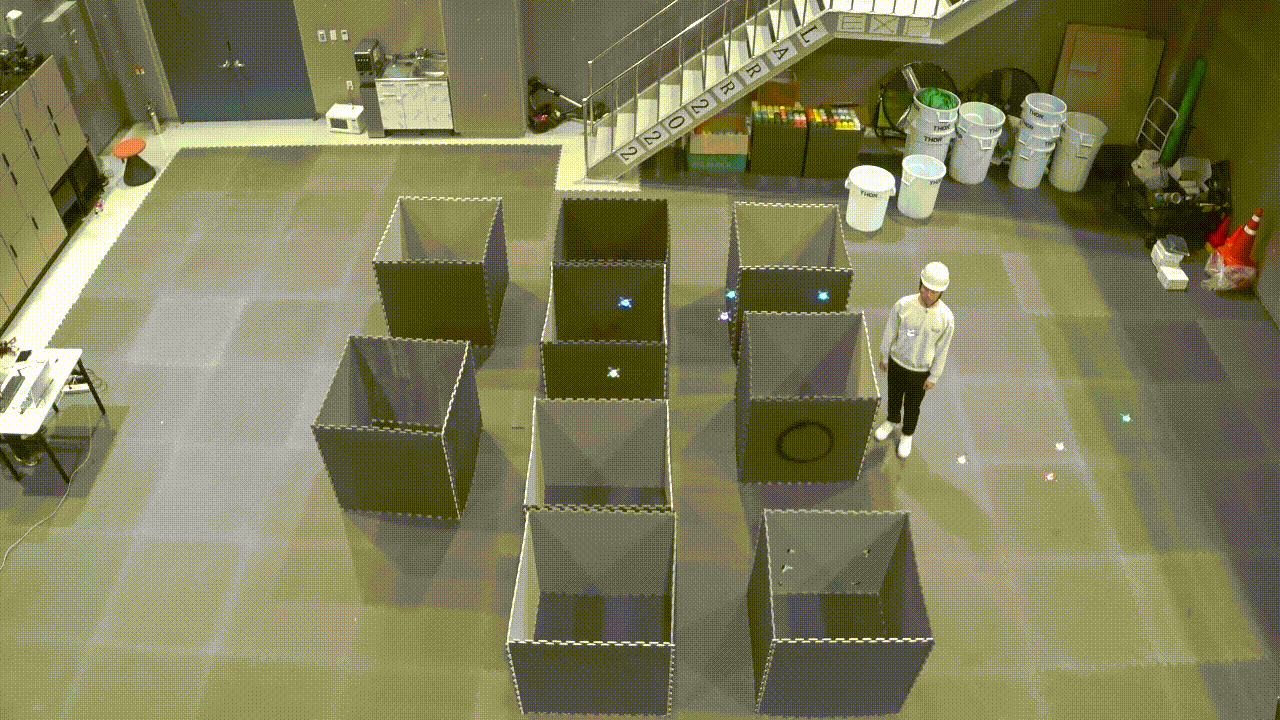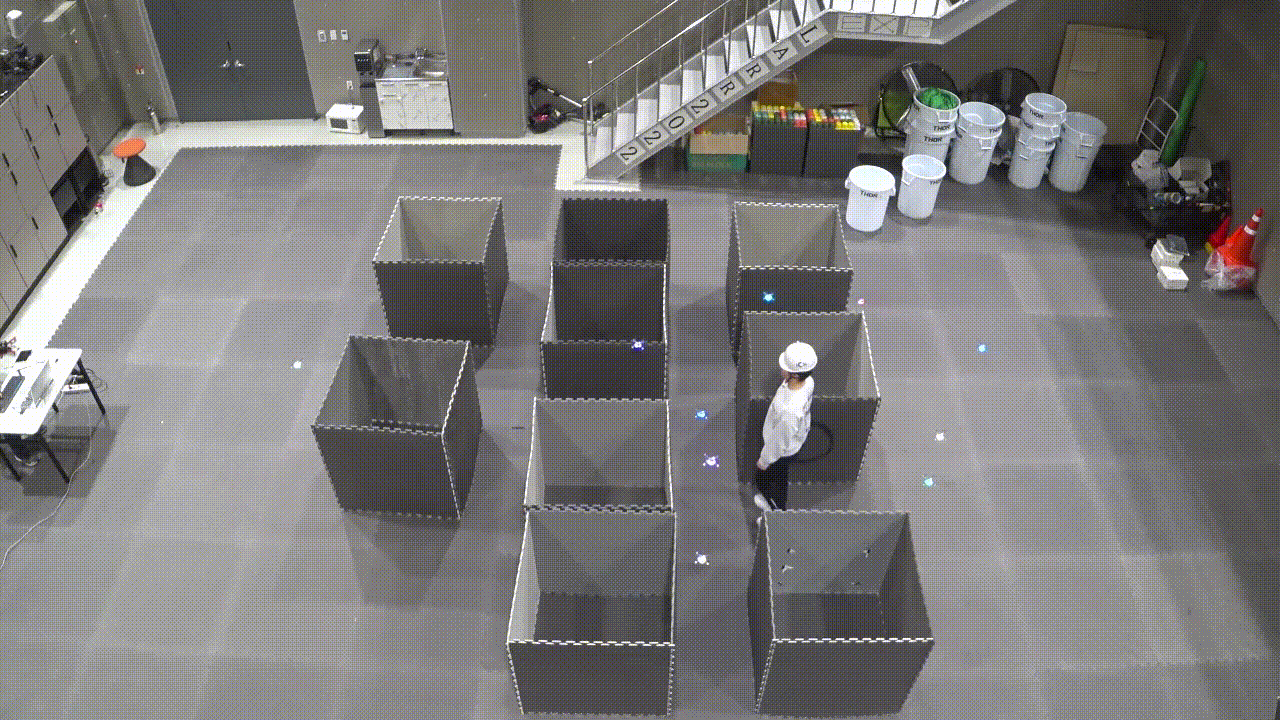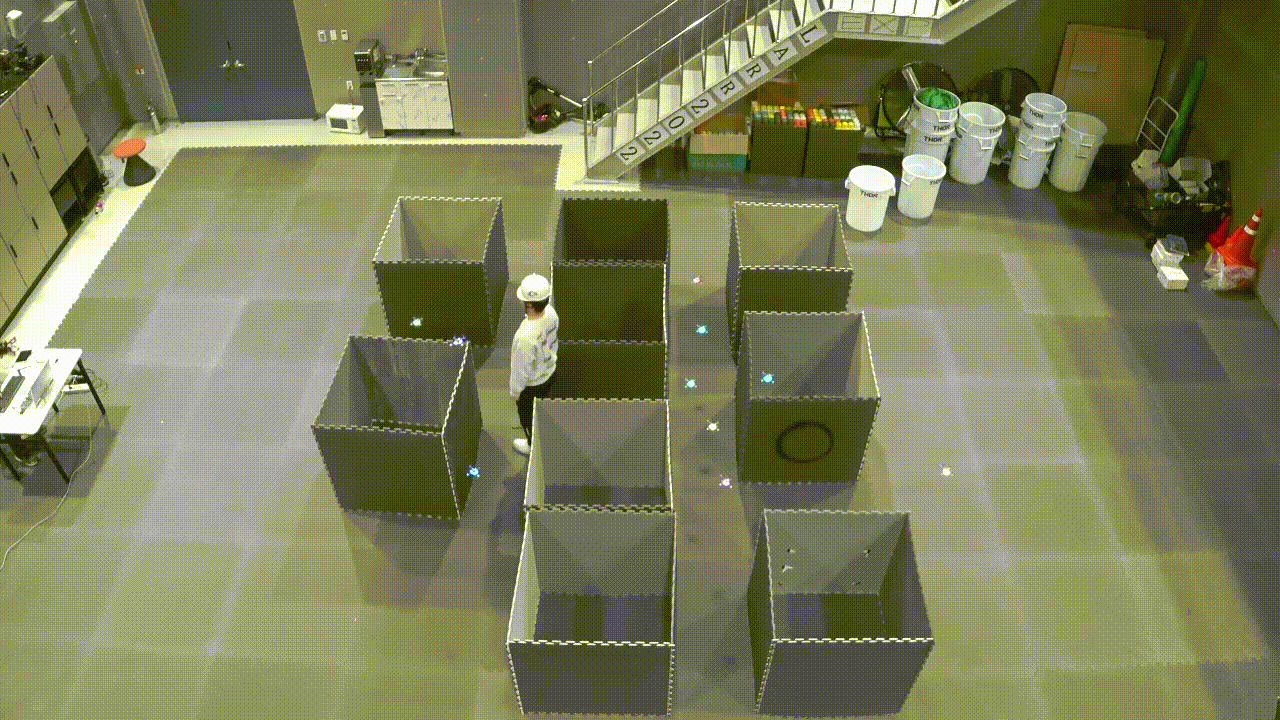
DMVC-Tracker: Distributed Multi-Agent Trajectory Planning for Target Tracking Using Dynamic Buffered Voronoi and Inter-Visibility Cells
Yunwoo Lee, Jungwon Park, H. Jin Kim RA-L, 2025 IEEE Xplore This paper presents a distributed trajectory planning method for multi-agent aerial tracking that enables collision-free and occlusion-aware tracking of a moving target in challenging environments. |

|
Decentralized trajectory planning for quadrotor swarm in cluttered environments with goal convergence guarantee
Jungwon Park, Yunwoo Lee, Inkyu Jang, H. Jin Kim IJRR, 2025 Sage This paper presents a decentralized trajectory planning method for quadrotor swarms that enables collision-free navigation in cluttered environments while guaranteeing convergence to assigned goals. |

|
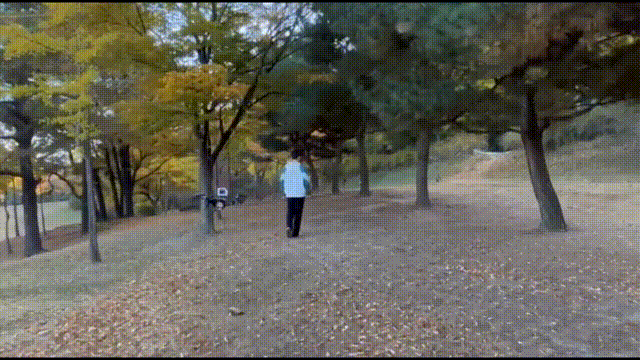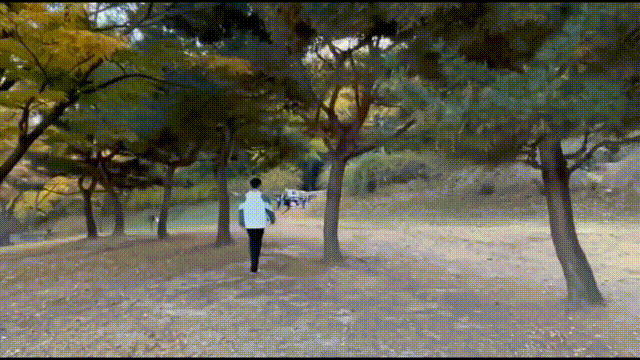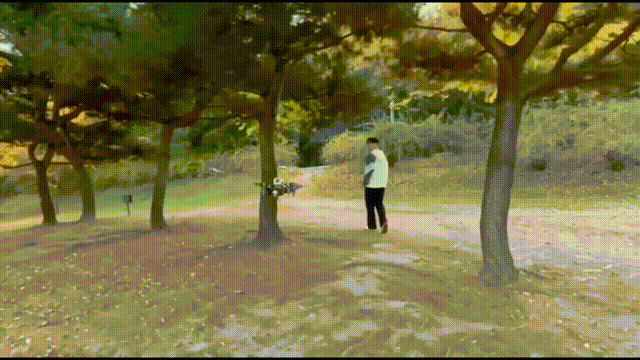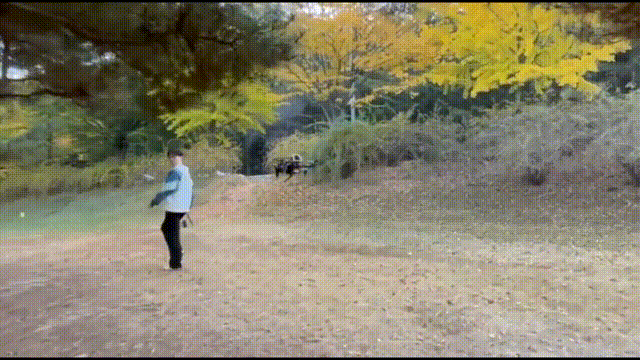
BPMP-Tracker: A versatile aerial target tracker using Bernstein polynomial motion primitives
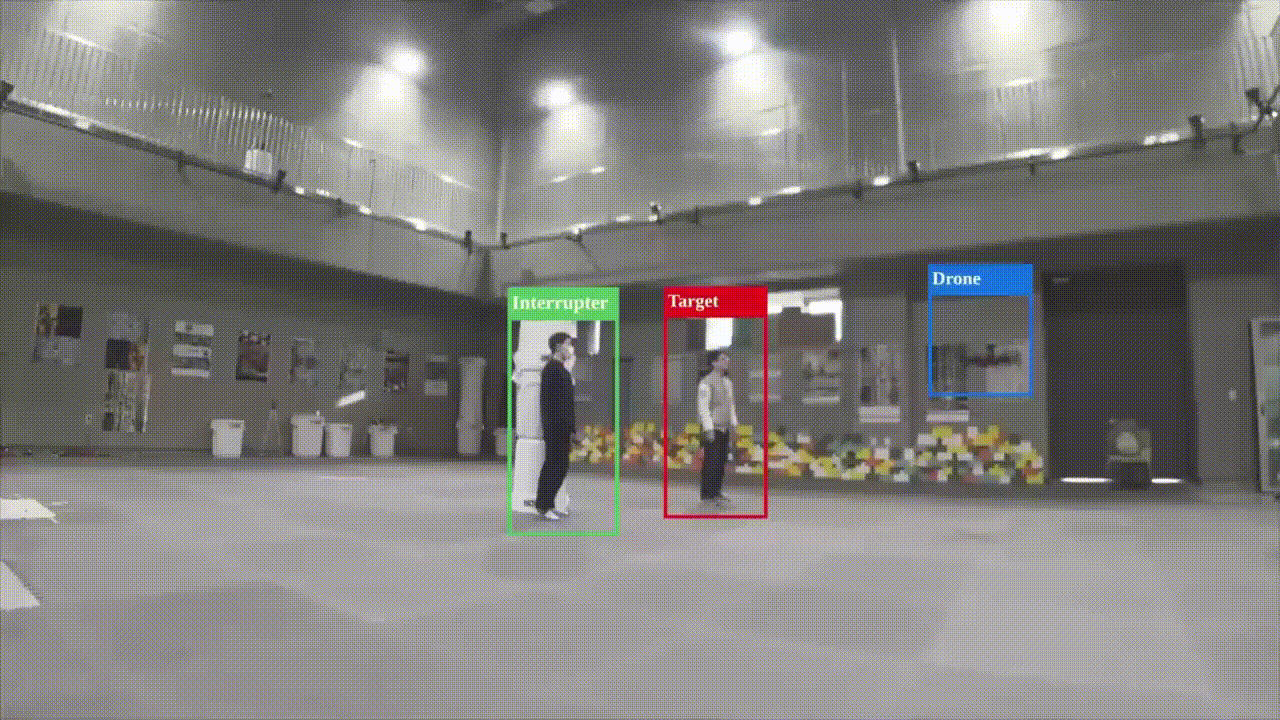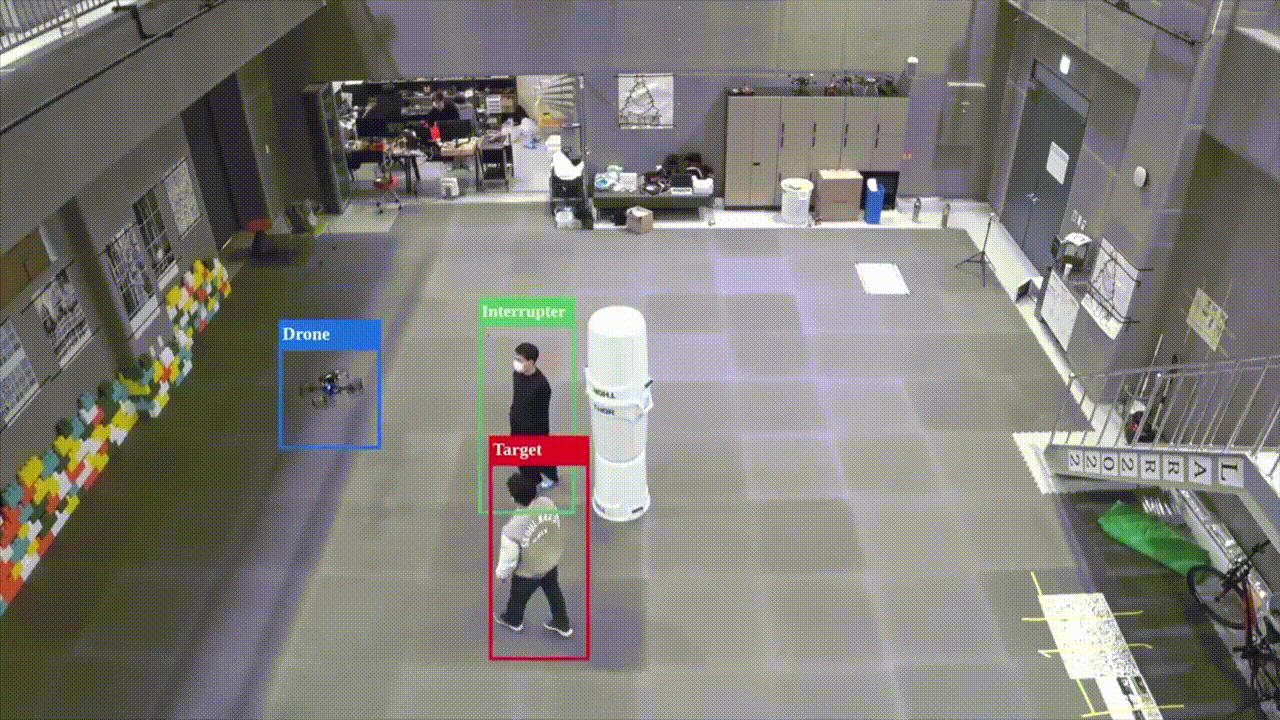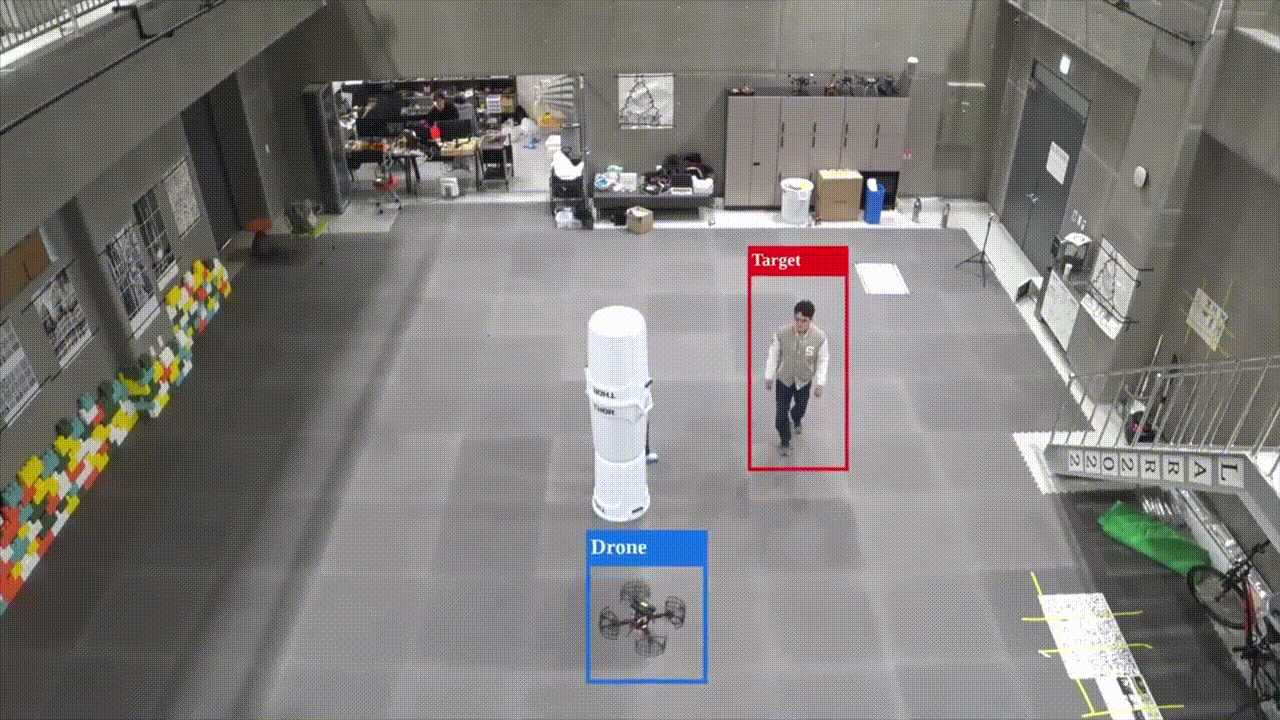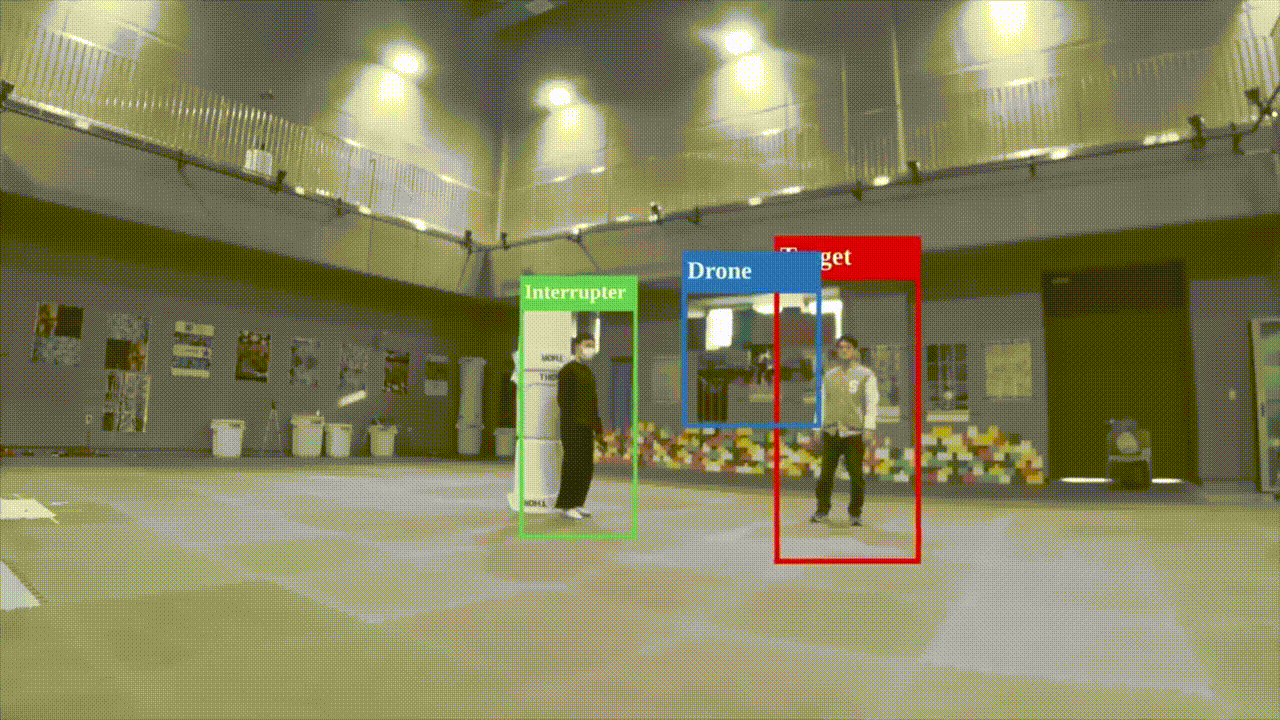
Yunwoo Lee, Jungwon Park, Boseong Jeon, Seungwoo Jung, H. Jin Kim RA-L, 2024 IEEE Xplore This paper presents a versatile aerial target tracking framework using Bernstein polynomial motion primitives for fast, collision-free, and occlusion-aware tracking in complex environments with dynamic obstacles and multiple targets. |
|
Mono-Camera-Only Target Chasing for a Drone in a Dense Environment by Cross-Modal Learning
Seungyeon Yoo, Seungwoo Jung, Yunwoo Lee, Dongseok Shim, H. Jin Kim RA-L, 2024 IEEE Xplore This paper presents a monocular-camera-only target chasing framework for drones that leverages cross-modal learning to enable robust target tracking and navigation in dense environments. |

|
DLSC: Distributed Multi-Agent Trajectory Planning in Maze-Like Dynamic Environments Using Linear Safe Corridor
Jungwon Park, Yunwoo Lee, Inkyu Jang, H. Jin Kim T-RO, 2023 IEEE Xplore This paper presents a distributed multi-agent trajectory planning method using linear safe corridors for collision-free navigation in maze-like dynamic environments. |
|
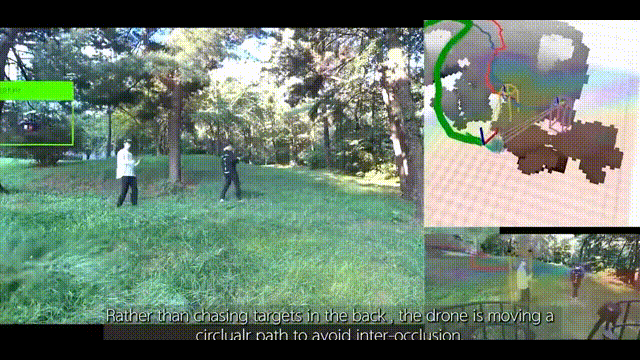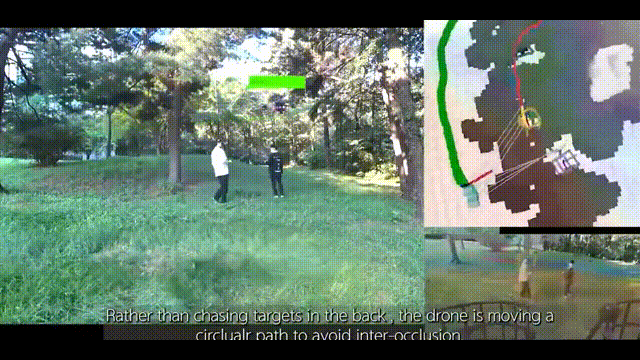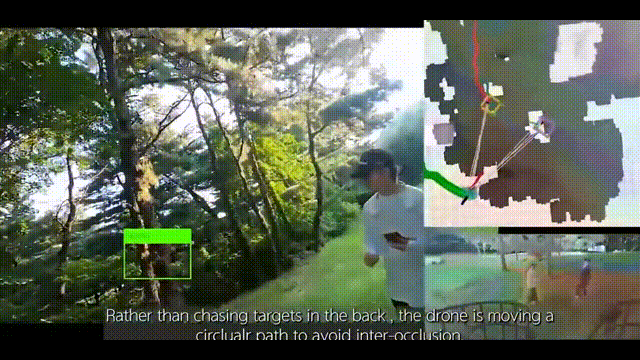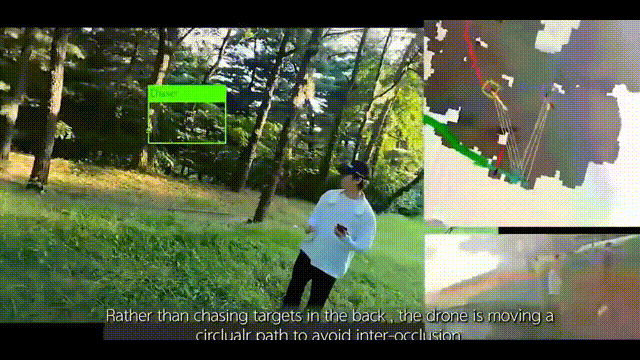
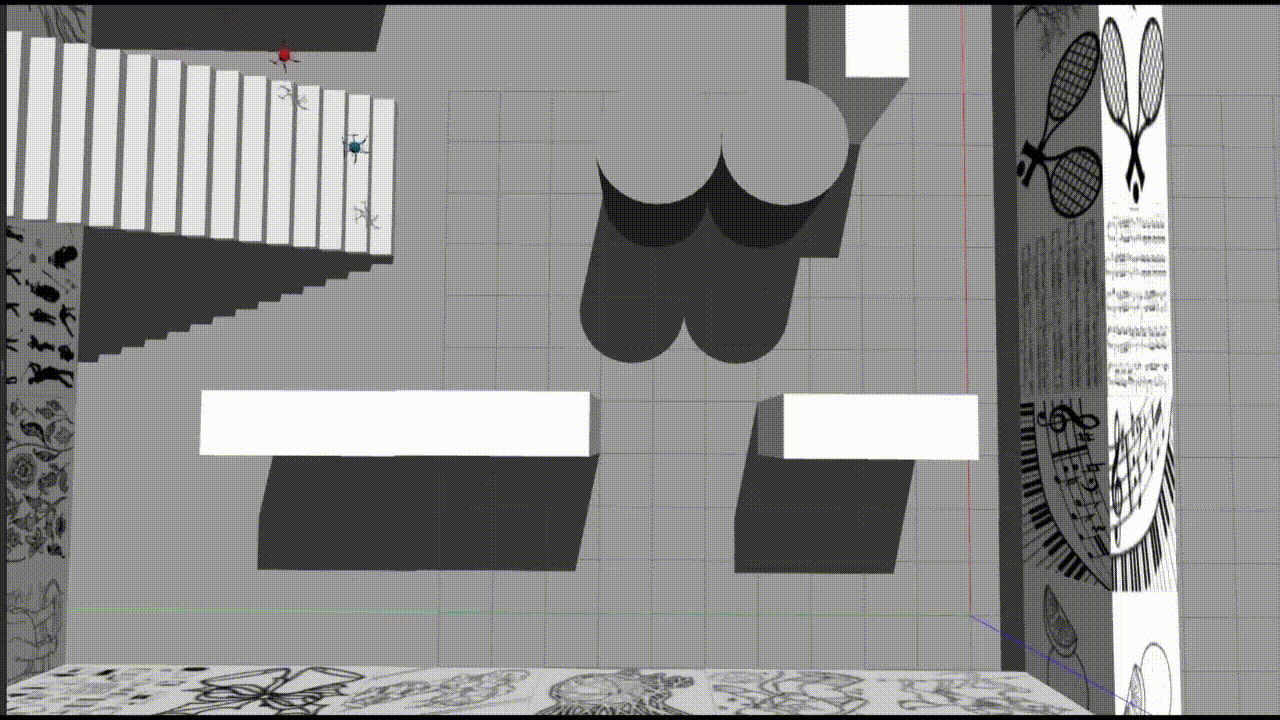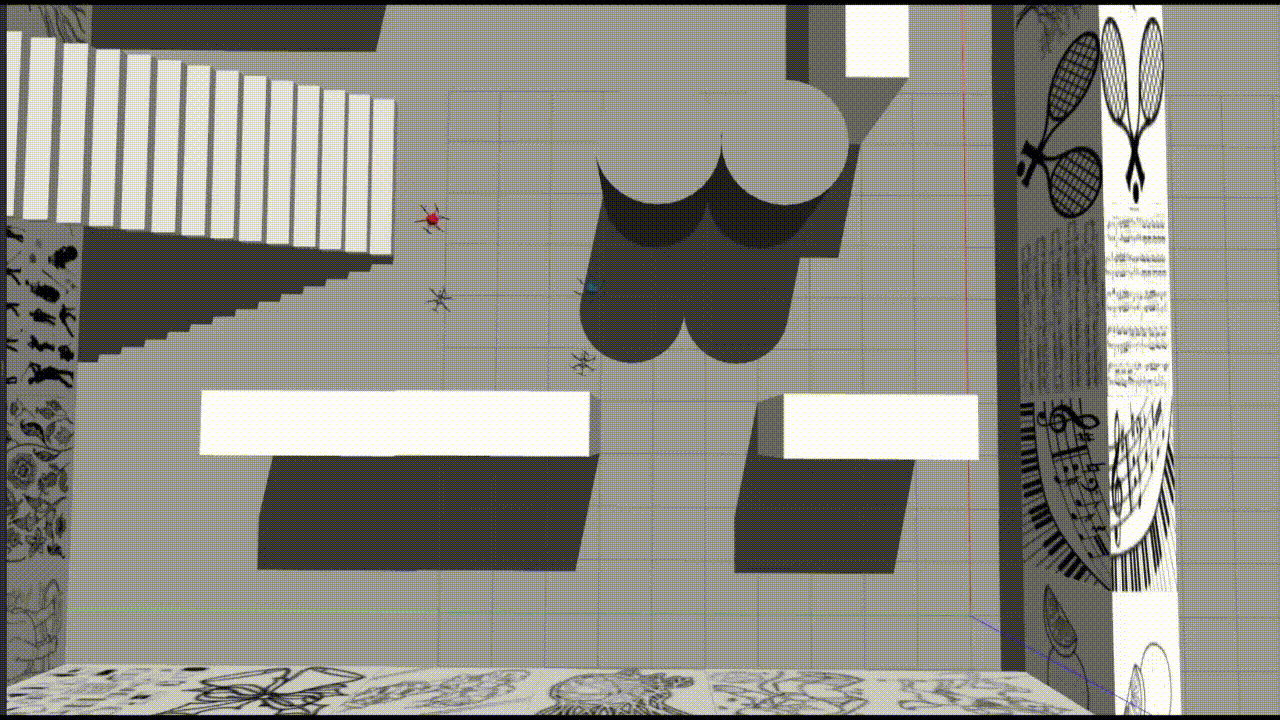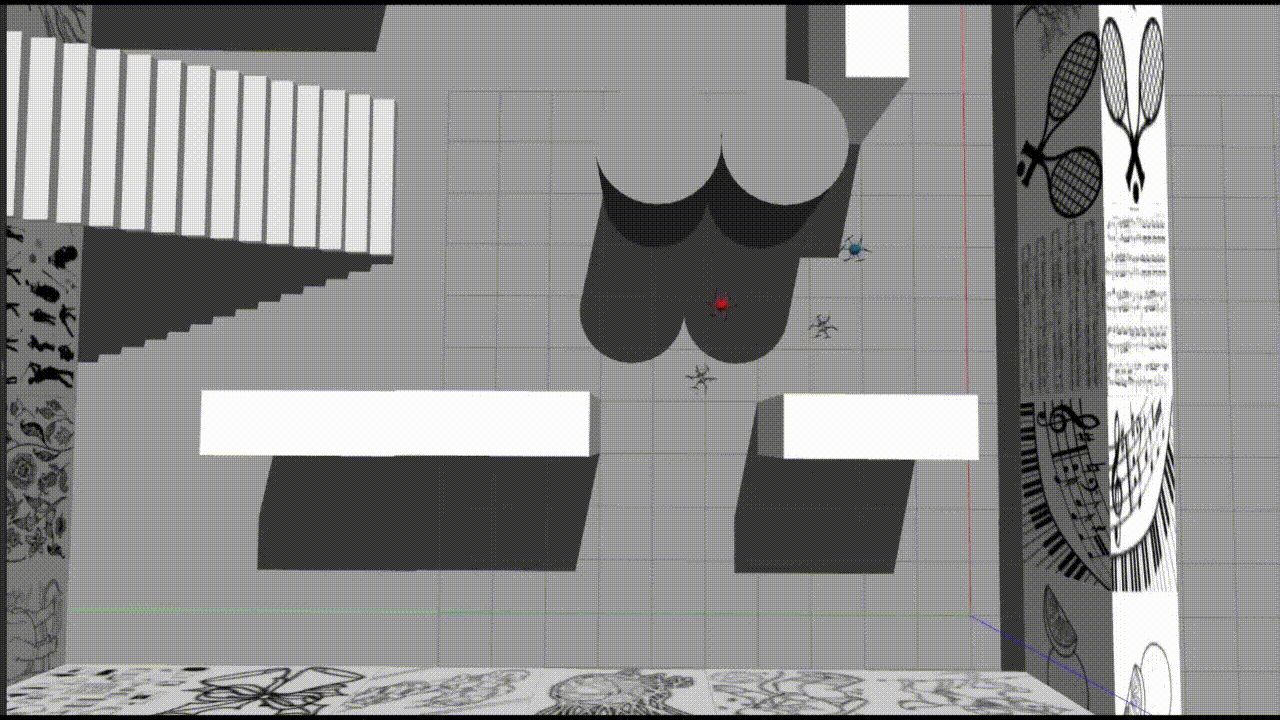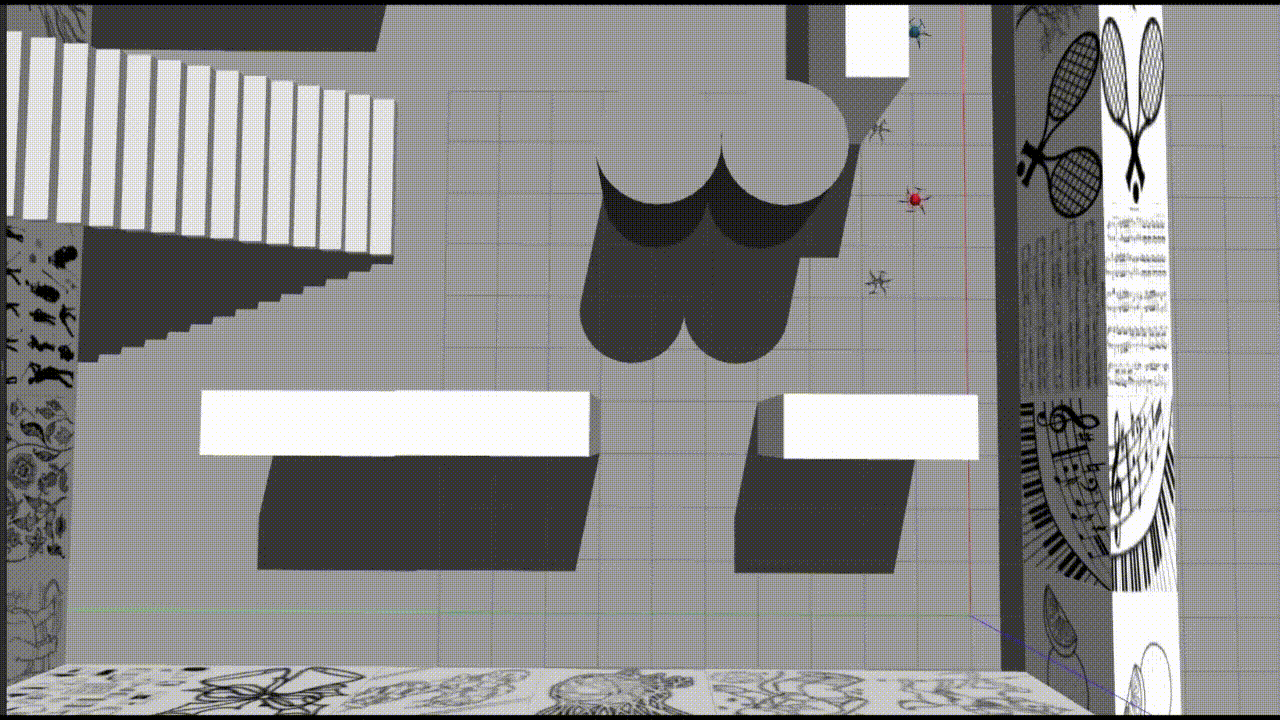
Autonomous Aerial Dual-Target Following Among Obstacles
Boseong Jeon, Yunwoo Lee, Jeongjun Choi, Jungwon Park, H. Jin Kim Access, 2021 IEEE Xplore This paper presents an autonomous aerial dual-target following framework that enables a drone to track two moving targets while handling obstacles, limited field of view, and inter-target occlusions. |
|
Target-visible polynomial trajectory generation within an mav team
Yunwoo Lee, Jungwon Park, Boseong Jeon, H. Jin Kim IROS, 2021 IEEE Xplore This paper presents a polynomial trajectory planning method for MAV teams that maintains continuous target visibility. |
|
Multirobot Collaborative Monocular SLAM Utilizing Rendezvous
Youngseok Jang, Changsuk Oh, Yunwoo Lee, H. Jin Kim T-RO, 2021 IEEE Xplore This paper presents a method for collaborative monocular SLAM using rendezvous strategies. |
|
Navigation-assistant path planning within a mav team
Youngseok Jang*, Yunwoo Lee*, H. Jin Kim IROS, 2020 IEEE Xplore This paper presents a navigation-assistant path planning method in which a supporting MAV actively plans its path to improve the localization and navigation performance of a main MAV. |
|
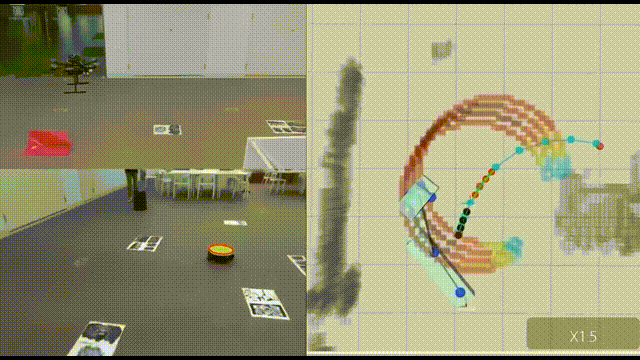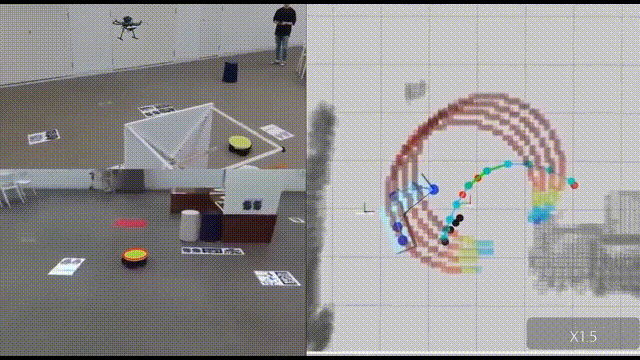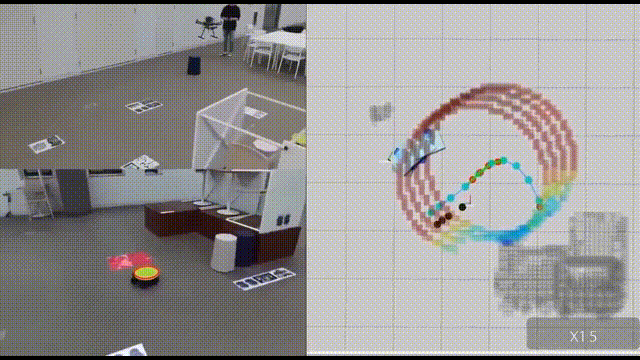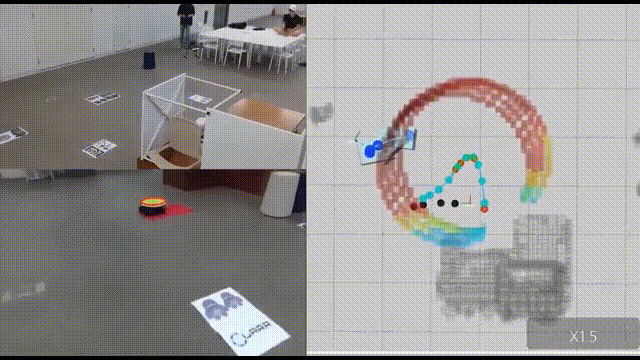
Integrated Motion Planner for Real-time Aerial Videography with a Drone in a Dense Environment
Boseong Jeon, Yunwoo Lee, H. Jin Kim ICRA, 2020 IEEE Xplore This paper presents an integrated motion planning framework for autonomous aerial videography that combines target motion prediction with visibility-aware trajectory planning to safely follow a moving target in dense environments. |